Robot training data, recorded in the real world and labelled to your rules.

Checked recording by recording, delivered ready to train on. Use collection, annotation or both.

action: pour

Partners

Records
1.5M+
Hours recorded
11,900+
Total size
76 TB+
Partners
4

Problem

Robots lack real-world data, and what exists waits on labels.

Language models learned from the internet. Robots have no internet of physical work, so teams record their own, then label it frame by frame.

What 10 hours of footage really is
10 hours of video36,000 seconds
Each second is 30 frames1,080,000 frames
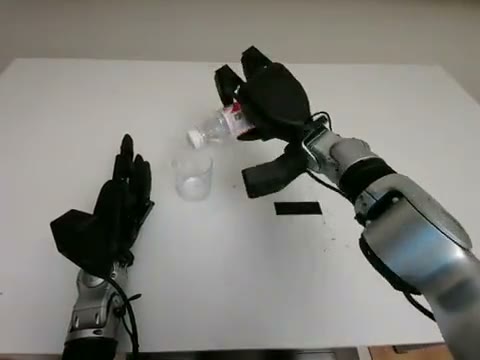
One frame: a robot hand tilting a bottle over a cup, with boxes around the hand, bottle and cup.
Each frame has objects to box 3,240,000 boxes
  • right hand
  • bottle
  • cup
At 30 frames a second, with three tracked objects in every frame.

What we do

Two products, used alone or together.

  1. Record
  2. Check
  3. Label
  4. Deliver
CollectionWe record it, then label it
You send footage
AnnotationWe label it

Collection

Demonstrations recorded to your task list.

  • Egocentric
  • Handheld gripper
  • Teleoperation
  • Four partners
See collection
Head-camera frame of a robot hand tilting a bottle over a cup, with labelled boxes around the hand, bottle and cup. action: pour

Annotation

Your recordings, labelled in your schema.

  • Boxes
  • Tracks
  • Action segments
  • Task descriptions
See annotation

Capture

Three ways to record a demonstration.

Head camera

Egocentric

  • Video
  • Both hands
  • Objects handled

No robot needed

Handheld gripper

  • Wrist video
  • Position
  • Opening width

On your robot

Teleoperation

  • Robot cameras
  • Joint state
  • Operator commands

How it works

You check the data fits before anyone records at volume.

Write the task list

One short script per task. Already have footage? Skip to step 4.

task:     pour water
start:    bottle upright on the table
end:      bottle back on the table
may vary: cup position, fill level, room

Test a pilot week

Load a small batch into your training code before any larger order.

scope:    a few tasks, a few locations
time:     one week
your job: load it, train on it, decide

Partners record

In places matched to your list.

capture:  head camera | phone | fixed camera
sites:    matched to your task list
consent:  on record for every contributor

Check and label

From our public sample clip.

tracks:   right hand, bottle, cup
segments: grasp, tilt, pour, return
check:    28 frames, 9 corrections logged

Receive weekly batches

In your format, with the rules and a check log.

format:   your schema; Parquet and MP4 by default
rules:    included with each batch
check:    log included with each batch
access:   private, access-logged repository

Quality

Every batch shows how it was made.

What ships with each batch
  • recordings/Passed the intake check
  • labelsIn your schema
  • rulesAction names, start and end of each segment
  • check logFrames checked, corrections made
  • consentOn record, for collected data

Case studies

How a research lab and a startup got months of data work done in weeks.

Tell us what you're training and what data you have.

Start with a pilot before any larger order.